Area sweep
Systematic sector search with configurable grid spacing, heading and overlap.
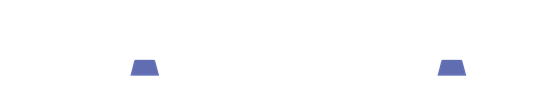
Give the fleet an objective. Altiro puts distributed coordination onboard, so participating platforms can share mission state and organize their contributions across the systems you already use.
Each FPV platform, or group of about five autonomous ones, needs a dedicated operator. Fleet size is capped by operator training.
When the link to the ground station degrades, the fleet returns to base or breaks into individually controlled platforms.
Mixed fleets need custom one-to-one integrations, or run as parallel systems the operator must coordinate in their head.
The network link back to the operator reveals where they are.
Sharing across services or partners means custom integration into one side's command system, or commanders calling each other.
Patterns can be configured through API or JSON interfaces, according to the capabilities of the domain-specific autopilot.
Systematic sector search with configurable grid spacing, heading and overlap.
V-formation, line or custom geometry, with synchronization at waypoints.
Hold above an area of interest, ready for re-tasking as the mission changes.
Break from the current task to investigate a location, then return to assigned duties.
Search outward from a center point along a spiral with a growing radius.
Combine waypoint sequences and coordination rules supported by your platform’s autopilot.
Open MAVLink-based ArduPilot/PX4 systems. One Raspberry Pi Zero, or one Arm/x86 core, per node. IP-based network.
As an enabling software layer. Demonstrated full-stack with field integration partners at Edwards AFB and Twentynine Palms in 2026.
Application-layer C2, mission logic, sensor fusion, COP interfaces, or network and comms technology.
Watch the April 2026 demo, or talk to us about integrating your platform.